ESAC6A
ESAC6A is an IEEE Type AC excitation system with sensed terminal-voltage feedback, cascaded regulator lead–lag blocks, voltage-regulator limits, an exciter alternator state, field-current feedback limiting, rectifier loading, saturation, and optional speed multiplier.
Warning
Initialization does not yet invert the smooth gates and limits used by the model equations.
Notes
Internal voltage and current signals are on model base unless otherwise stated.
The rectifier loading block \(F_{\mathrm{ex}}=f(I_N)\) is the source AC-exciter loading curve from Fig. 1; it is not a CommonMath helper.
The source diagram labels the optional multiplier input as
Speed; GridKit uses machine speed deviation, so the enabled multiplier is \(1+\omega\).
Block Diagram
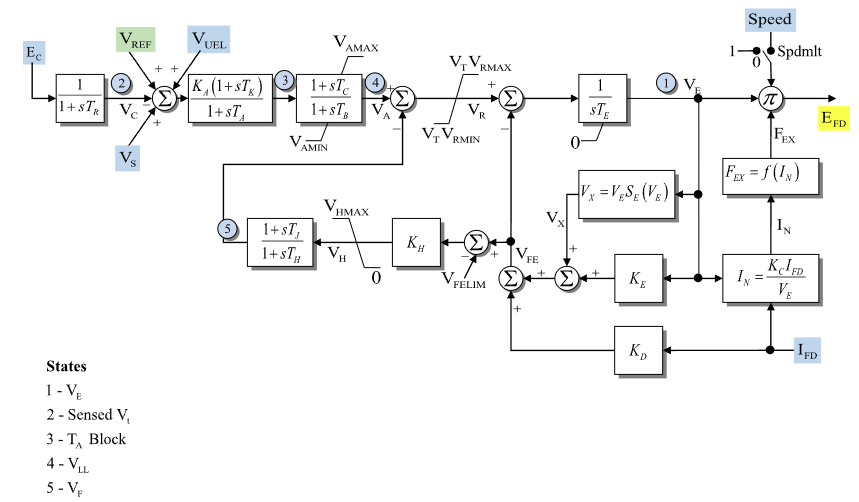
Figure 1: Exciter ESAC6A model. Figure courtesy of PowerWorld
Model Parameters
Symbol |
Units |
JSON |
Description |
Typical Value |
Note |
|---|---|---|---|---|---|
\(T_R\) |
[s] |
|
Transducer time constant |
0.0 |
if zero, \(V_C\) is algebraic |
\(K_A\) |
[p.u.] |
|
Voltage-regulator gain |
40.0 |
|
\(T_A\) |
[s] |
|
Regulator denominator time constant |
0.1 |
|
\(T_K\) |
[s] |
|
Regulator numerator time constant |
0.0 |
|
\(T_B\) |
[s] |
|
Lag time constant for second lead–lag block |
0.0 |
|
\(T_C\) |
[s] |
|
Lead time constant for second lead–lag block |
0.0 |
|
\(V_A^{\max}\) |
[p.u.] |
|
Maximum first regulator block output |
1.0 |
Source label: |
\(V_A^{\min}\) |
[p.u.] |
|
Minimum first regulator block output |
-1.0 |
Source label: |
\(V_R^{\max}\) |
[p.u.] |
|
Maximum voltage-regulator output |
1.0 |
|
\(V_R^{\min}\) |
[p.u.] |
|
Minimum voltage-regulator output |
-1.0 |
|
\(T_E\) |
[s] |
|
Exciter alternator time constant |
0.5 |
|
\(V_{\mathrm{FE}}^{\mathrm{lim}}\) |
[p.u.] |
|
Feedback-limiter summing-junction reference |
0.0 |
Source label: |
\(K_H\) |
[p.u.] |
|
Feedback-limiter gain |
1.0 |
Source label: |
\(V_H^{\max}\) |
[p.u.] |
|
Maximum feedback-limiter lead–lag output |
1.0 |
Source label: |
\(T_H\) |
[s] |
|
Feedback-limiter denominator time constant |
0.0 |
Source label: |
\(T_J\) |
[s] |
|
Feedback-limiter numerator time constant |
0.0 |
Source label: |
\(K_C\) |
[p.u.] |
|
Rectifier loading current coefficient |
0.0 |
forms \(I_N\) |
\(K_D\) |
[p.u.] |
|
Demagnetizing factor feedback gain |
0.0 |
|
\(K_E\) |
[p.u.] |
|
Exciter field-resistance line-slope margin |
0.1 |
|
\(E_1\) |
[p.u.] |
|
First saturation voltage point |
2.8 |
|
\(S_E(E_1)\) |
[p.u.] |
|
Saturation value at \(E_1\) |
0.08 |
Source label: |
\(E_2\) |
[p.u.] |
|
Second saturation voltage point |
3.7 |
|
\(S_E(E_2)\) |
[p.u.] |
|
Saturation value at \(E_2\) |
0.33 |
Source label: |
\(s_{\mathrm{spd}}\) |
[binary] |
|
Speed multiplier flag |
0 |
1 enables the speed multiplier |
Parameter Validation
A valid ESAC6A parameter set must satisfy the following conditions:
The saturation points are either disabled together or define a valid positive two-point quadratic fit.
Model Derived Parameters
The saturation curve is fitted from the two supplied saturation points. If both saturation factors are zero, use \(S_A=0\) and \(S_B=0\). Otherwise:
Model Ports
Name |
Port |
Init |
Description |
|---|---|---|---|
|
Input |
TBD |
Compensated terminal voltage magnitude \(E_C\) |
|
Input |
TBD |
Voltage-control reference \(V_{\mathrm{ref}}\) |
|
Input |
TBD |
Under-excitation limiter input \(V_{\mathrm{uel}}\) |
|
Input |
TBD |
Stabilizer input signal \(V_S\) |
|
Input |
TBD |
Machine field current \(I_{\mathrm{fd}}\) |
|
Input |
TBD |
Machine speed deviation \(\omega\) |
|
Output |
TBD |
Field-voltage output \(E_{\mathrm{fd}}\) |
Model Variables
Internal Variables
Differential
Symbol |
Units |
Description |
Note |
|---|---|---|---|
\(V_E\) |
[p.u.] |
Exciter alternator voltage state before output multipliers |
State 1 in Fig. 1; Source label: |
\(V_C\) |
[p.u.] |
Sensed compensated voltage |
State 2 in Fig. 1; Source label: |
\(x_A\) |
[p.u.] |
First regulator lead–lag denominator state |
State 3 in Fig. 1; Source label: |
\(x_{\mathrm{LL}}\) |
[p.u.] |
Second lead–lag denominator state |
State 4 in Fig. 1; Source label: |
\(V_F\) |
[p.u.] |
Stabilizing feedback signal |
State 5 in Fig. 1; Source label: |
Algebraic
Symbol |
Units |
Description |
Note |
|---|---|---|---|
\(e_V\) |
[p.u.] |
Voltage-regulator input error before first lead–lag |
Summing junction after sensed voltage |
\(V_A\) |
[p.u.] |
Limited first regulator lead–lag output |
Limited by \(V_A^{\min}\) and \(V_A^{\max}\) |
\(V_{\mathrm{LL}}\) |
[p.u.] |
Second lead–lag output |
Input to \(V_R\) summing junction |
\(V_H\) |
[p.u.] |
Feedback-limiter lead–lag output before \(K_H\) |
Limited by 0 and \(V_H^{\max}\) |
\(V_H^{\mathrm{pre}}\) |
[p.u.] |
Feedback-limiter lead–lag output before limits |
Bypasses to \(V_F\) when \(T_H=T_J=0\) |
\(V_R\) |
[p.u.] |
Voltage-regulator output |
Limited by \(V_R^{\min}\) and \(V_R^{\max}\) |
\(S_E\) |
[p.u.] |
Saturation coefficient evaluated at \(V_E\) |
Uses derived saturation curve |
\(I_N\) |
[p.u.] |
Normalized exciter loading current |
Source label: |
\(F_{\mathrm{ex}}\) |
[p.u.] |
Rectifier loading factor |
Source label: |
\(V_{\mathrm{FE}}\) |
[p.u.] |
Exciter feedback signal |
Sum of saturation/resistance, \(K_D I_{\mathrm{fd}}\), and feedback-limiter paths |
\(E_{\mathrm{fd}}\) |
[p.u.] |
Field-voltage output |
Output after rectifier loading and optional speed multiplier |
External Variables
Differential
None.
Algebraic
Symbol |
Units |
Description |
Note |
|---|---|---|---|
\(E_C\) |
[p.u.] |
Compensated terminal voltage magnitude |
Source label: |
\(V_{\mathrm{ref}}\) |
[p.u.] |
Voltage-control reference |
Source label: |
\(V_{\mathrm{uel}}\) |
[p.u.] |
Under-excitation limiter input |
Source label: |
\(V_S\) |
[p.u.] |
Stabilizer input signal |
Source label: |
\(I_{\mathrm{fd}}\) |
[p.u.] |
Machine field current |
Source label: |
\(\omega\) |
[p.u.] |
Machine speed deviation |
Source label: |
Model Equations
Smooth functions: clamp, \(q\).
Internal Equations
Differential
Algebraic
When \(T_B=T_C=0\), the second lead–lag block is bypassed. When \(T_H=T_J=0\), the feedback-limiter lead–lag block is bypassed before the 0-to-\(V_H^{\max}\) clamp.
External Equations
None.
Initialization
The machine initializes \(E_{\mathrm{fd}}\) and \(I_{\mathrm{fd}}\) first. For a standard unsaturated start, ESAC6A reads those values and sets all internal derivatives to zero. First solve the coupled rectifier-loading equations:
Then evaluate:
This standard start requires \(1+s_{\mathrm{spd}}\omega\ne 0\), \(V_E\ne 0\), inactive \(V_A\), \(V_R\), and \(V_H\) limits, and nonsingular regulator gains/time constants. Starts that bind those limits are outside these closed-form equations.
Monitors
Monitor |
Units |
Description |
Note |
|---|---|---|---|
|
[p.u.] |
Field-voltage output |
\(E_{\mathrm{fd}}\) |
|
[p.u.] |
Exciter alternator voltage state |
\(V_E\) |
|
[p.u.] |
Sensed compensated voltage |
\(V_C\) |
|
[p.u.] |
First regulator output |
\(V_A\) |
|
[p.u.] |
Second lead–lag output |
\(V_{\mathrm{LL}}\) |
|
[p.u.] |
Feedback-limiter state |
\(V_F\) |
|
[p.u.] |
Feedback-limiter output |
\(V_H\) |
|
[p.u.] |
Voltage-regulator output |
\(V_R\) |
|
[p.u.] |
Normalized exciter loading current |
\(I_N\) |
|
[p.u.] |
Rectifier loading factor |
\(F_{\mathrm{ex}}\) |
|
[p.u.] |
Saturation coefficient |
\(S_E\) |